In brief

Choose a polishing application route from the actual components and required final appearance. Record the material, geometry, incoming finish and presentation range, then define how the result will be assessed; a sector name alone does not establish suitability.

Repeatable production and a retrofit or flexible cell raise different questions about part location, tooling, changeover and line connections. Use the existing application guides below to define the range and evidence required before choosing an arrangement.

On the production floor

Match the solution to your product, part and operating needs — Robotic Polishing Cells

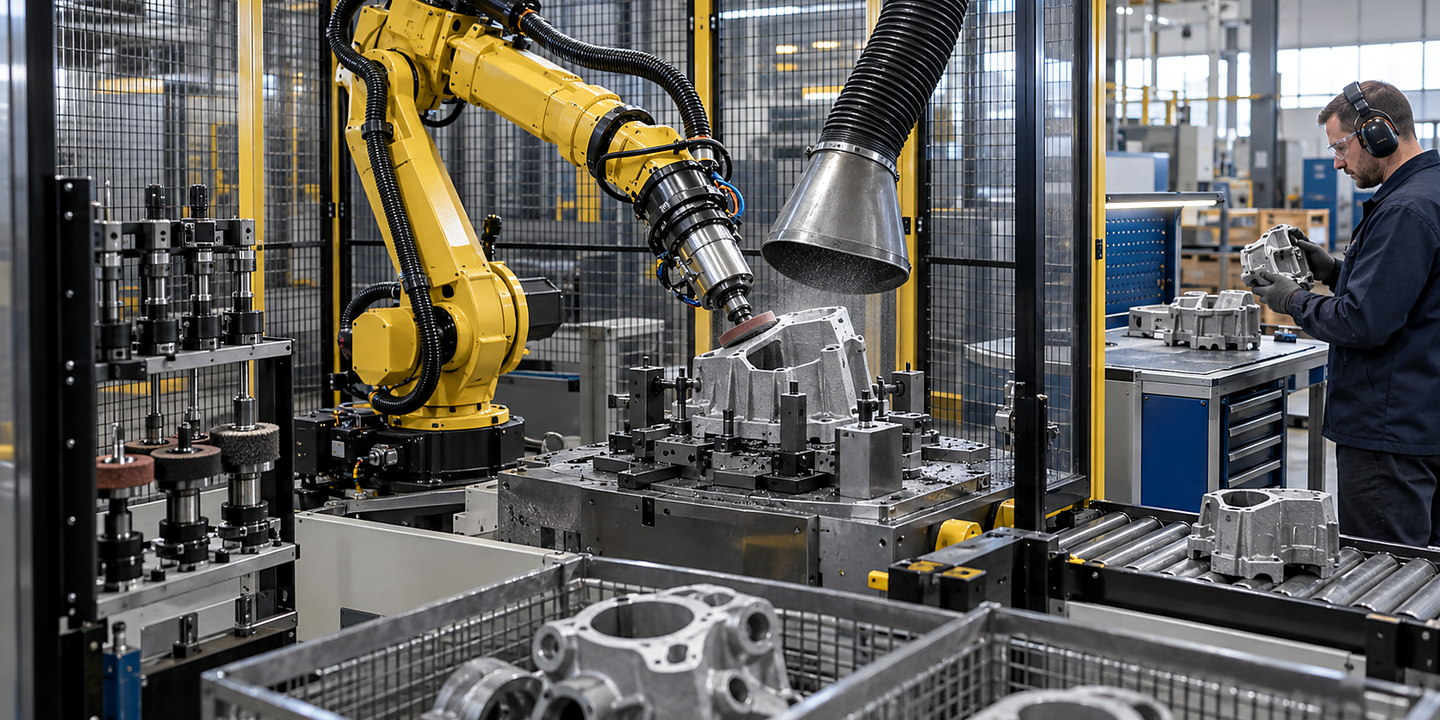
Plan robotic polishing cells around your parts, process, cycle time, tooling, recovery and acceptance criteria. Discuss the highest-risk feasibility questions with Oxford Industrial Automation. Use the application examples to compare repeatable production using robotic surface-polishing cells with retrofit or flexible cells involving robotic surface-polishing cells.

Discuss your application
Application 1

Repeatable Production Using Robotic Surface-Polishing Cells

Define the component range, incoming finish and required final appearance for the intended production pattern. Assess part location, tooling and the polishing sequence together, including tool wear, process variation and the finished-part check.

Explore this application
Application 2

Retrofit or Flexible Cells Involving Robotic Surface-Polishing Cells

Record the existing layout and interfaces, then identify the component variants and proposed changes. Assess their effect on part location, tooling, changeover and appearance checking; do not assume an arrangement proven for one component transfers to another.

Explore this application
Choose the right route

Four questions that can change the recommended approach

What arrives?

Provide representative components spanning material, geometry and incoming finish, with drawing revisions and arrival conditions. Identify normal variation and the difficult cases the assessment must cover.

What must happen?

Define the surfaces and final appearance required and the method used to judge them. Keep the proposed polishing sequence and tooling separate from results that have been demonstrated on representative components.

What surrounds it?

Record part presentation and location, proposed tooling, line connections and the access needed for operation, cleaning, maintenance and changeover. Identify dependencies that remain outside the proposed cell scope.

What result do you need?

Agree representative samples, assessment method, repetitions and acceptable results. Record tool condition and process variation alongside the result, who reviews it and how finished parts or uncertain outcomes will be handled.

ApproachOften suitable whenWatch for
Robotic Polishing CellsYou need a dedicated solution for a clearly defined duty, product or part range and line interface.Cycle time depends on the complete process rather than robot speed alone.
Purpose-Built Mechanical Automation for a Stable, Very High-Volume TaskThe component range, presentation and required sequence are stable enough to investigate a dedicated mechanism.Assess part location, incoming finish, tool wear and the agreed appearance check, including the effect of future component or process changes.
Operator-Assisted Fixtures where Flexibility or Business Case Does Not Support a Robot CellVariant changes, manual presentation or operator judgement make an assisted fixture worth comparing with a robotic cell.Define operator tasks, access, the appearance assessment and the route for uncertain results, then compare the complete cycle.