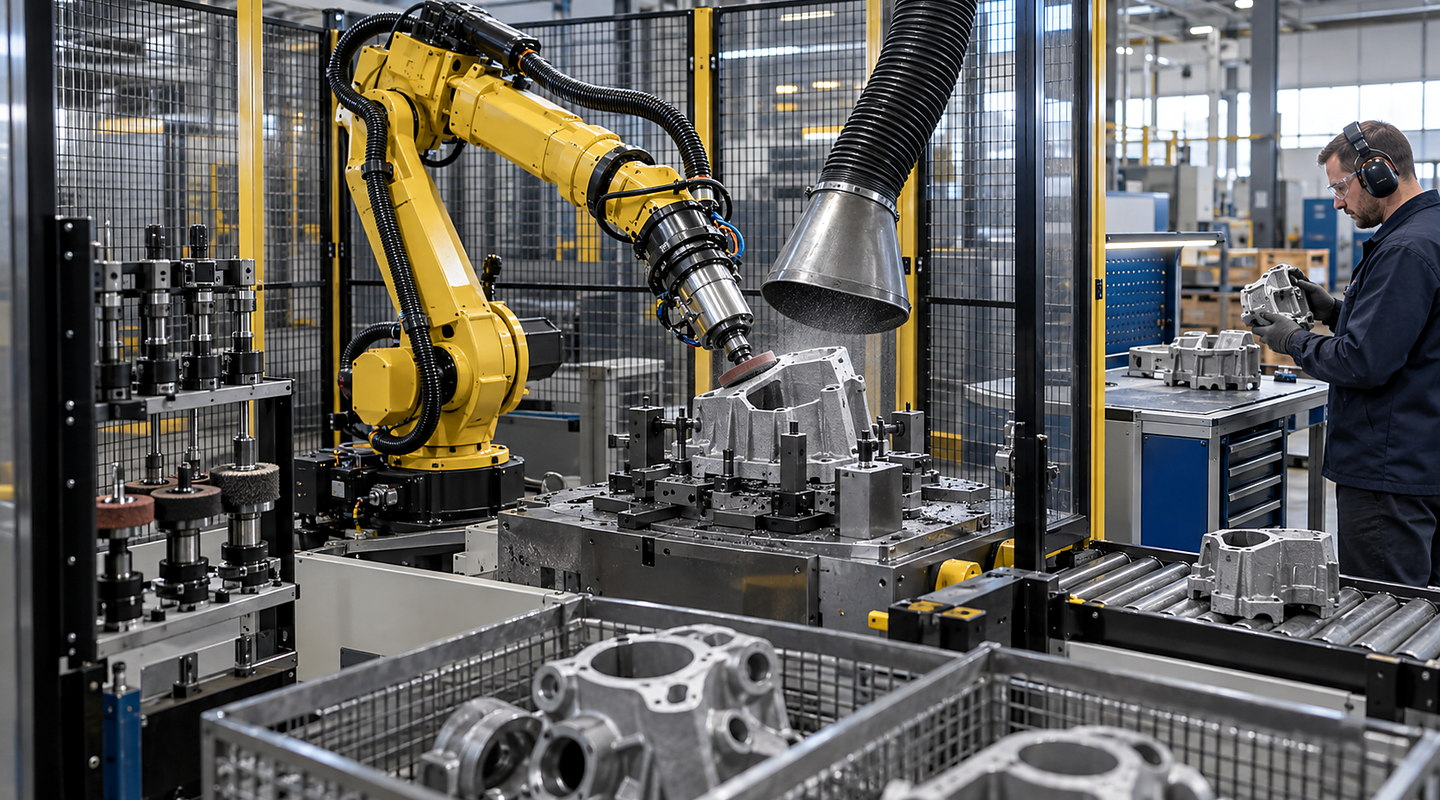
Plan robotic polishing cells around your parts, process, cycle time, tooling, recovery and acceptance criteria. Discuss the highest-risk feasibility questions with Oxford Industrial Automation.
Speak directly with Oxford Industrial Automation about robotic surface-polishing cells.
Quick answer
Can robotic polishing accommodate variation in our components?
Provide components spanning the material, geometry and incoming finish range. Define the required final appearance and the method used to assess it. Trial part location, tooling and the polishing sequence, including tool wear and process variation, before agreeing how finished parts and exceptions will be checked.
Six useful questions
Describe what you need from robotic polishing cells before choosing a solution
For repeatable production using robotic surface-polishing cells, share the normal condition, realistic range and difficult cases the finished system must handle.
Question 1
Part, Product and Process Variation for Robotic Surface-Polishing Cells
Provide components spanning the material, geometry and incoming finish range, with drawings and revision details. Include representative normal and difficult samples, and define the final appearance required and how it will be assessed.
Question 2
Arrival Pattern and Presentation
Describe how parts arrive and how they will be located for polishing. Include the normal presentation range and difficult cases so that part location, tooling and the polishing sequence can be considered together.
Question 3
Required Cycle and Production Pattern
State the required complete cycle and production pattern using current process observations and credible extremes. Compare the whole process sequence rather than specifying robot movement speed alone.
Question 4
Tooling, Sensing and Process Interfaces
Describe the tooling, sensing and line interfaces, including upstream and downstream states and external dependencies. Identify the tool wear and process variation that the feasibility work must address.
Question 5
Operator Access, Recovery and Changeover
Set out the access needed for operators, cleaning and maintenance, together with recovery and changeover cases. Include these in the application assessment without assuming that collaborative operation or automatic handling is safe.
Question 6
Run-Off Criteria and Production Evidence
Agree representative normal, difficult and fault scenarios, the assessment method, repetitions and acceptable results. Specify who reviews the result record, together with documentation, training, exclusions and controls for future changes.
Applications
Two useful starting points for robotic polishing cells
The right choice changes with part, product and process variation for robotic surface-polishing cells, arrival pattern and presentation, your line layout and required results.
Your route from an initial enquiry to a working solution
You can review decisions about operator access, recovery and changeover and run-off criteria and production evidence at each stage.
01
Observe the Current Process and Collect Representative Samples
Share representative parts, process observations and cycle data, including the normal range for part, product and process variation for robotic surface-polishing cells and the difficult arrival pattern and presentation cases.
02
Prove Handling and Process Risks in a Focused Feasibility Trial
Compare suitable methods and use focused trials to show how each option performs against required cycle and production pattern.
03
Design and Build the Complete Guarded Cell
Connect the equipment to your line, services and controls while resolving tooling, sensing and process interfaces for day-to-day operation.
04
Run Agreed Scenarios and Support Production Ramp-Up
Confirm operator access, recovery and changeover, then complete and record run-off criteria and production evidence before your operating team takes over.
Important limits
Know what needs a separate check
Cycle time depends on the complete process rather than robot speed alone.
Part presentation, tolerances and recovery cases must be included in feasibility work.
Collaborative operation or automatic handling cannot be assumed safe without an application assessment.
Your final solution for robotic surface-polishing cells must reflect the law, current standards and site-specific risks that apply to your installation.